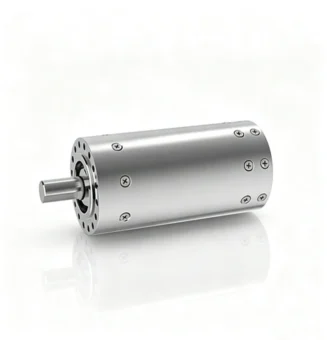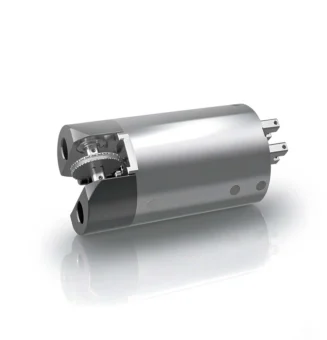
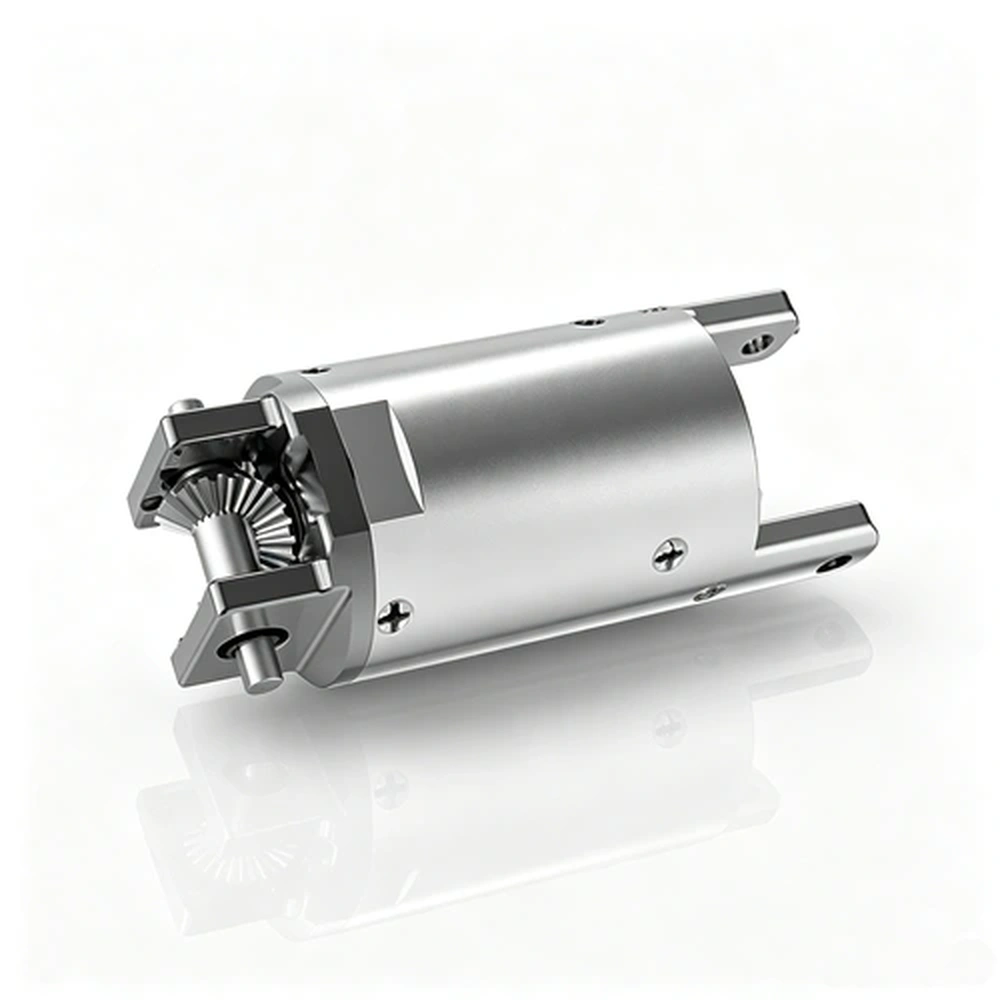
FM-RB-OD2032
& Free Shipping
Finger Joint Module
Small footprint, serious output — the ultra-light solution for dexterous hands and micro joints.
The RoBox Finger Joint Module is a complete micro-joint solution for dexterous hands — motor, reducer, encoder, and drive in one unit, ready to go. Three standard models (15 / 17 / 20 series) span 15–20 mm, with each joint from just 25 g — among the lightest micro joints in the industry.
Free shipping on orders over $50!
- Satisfaction Guaranteed
- No Hassle Refunds
- Secure Payments
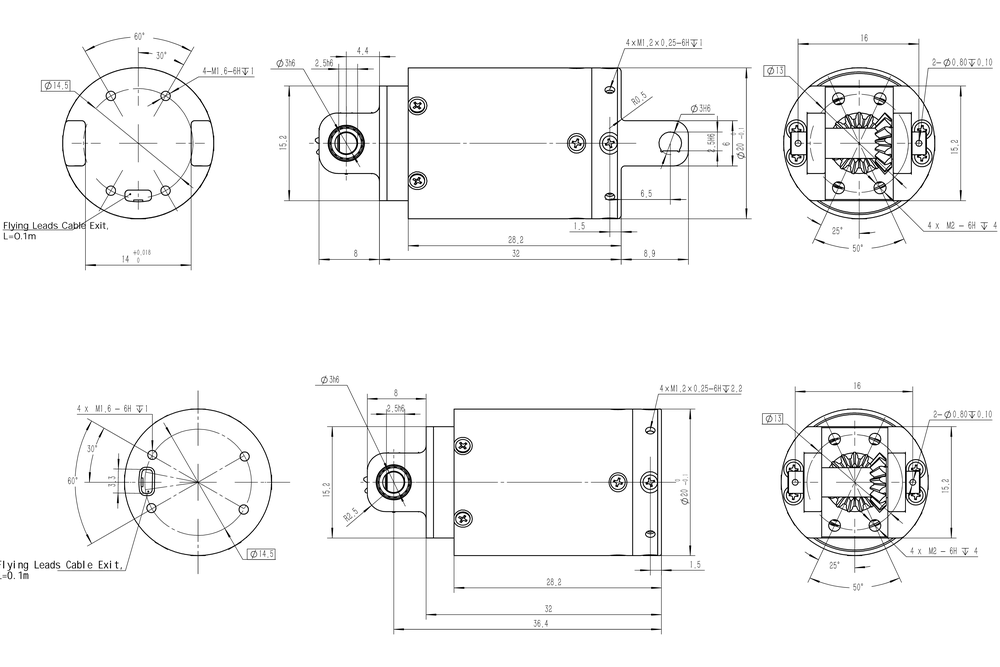
Specifications
Gear Ratio
30.25
Continuous Torque
0.2 / 0.25 Nm
Intermittent Torque
0.6 Nm (<2s)
Rated Speed
48 rpm
Voltage
12 / 24 V
Communication Interface
RS485 / CAN
Resolution
14-Bit
Weight
Approx. 40 g
Product Type
Finger Joint Module
Peak Speed
48 rpm
Encoder
Single-Turn Absolute
Rated Load Phase Current
1.46 A (12V) / 0.96 A (24V)
Peak Phase Current
3.5 A (12V) / 2.95 A (24V)
Driver
Integrated
Hollow Diameter
None
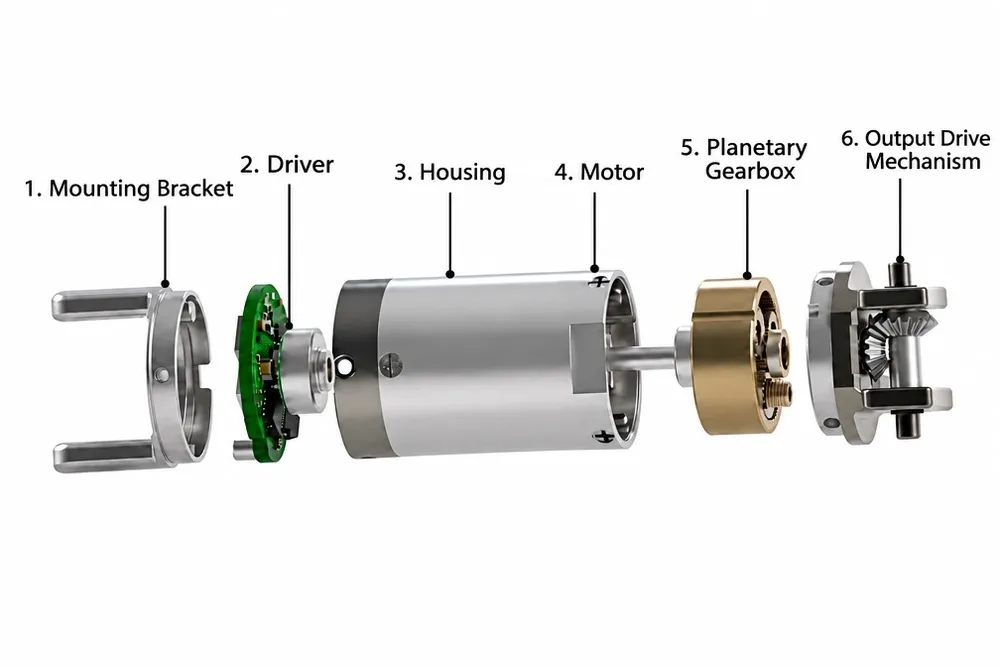
1. Micro Brushless Frameless Motor
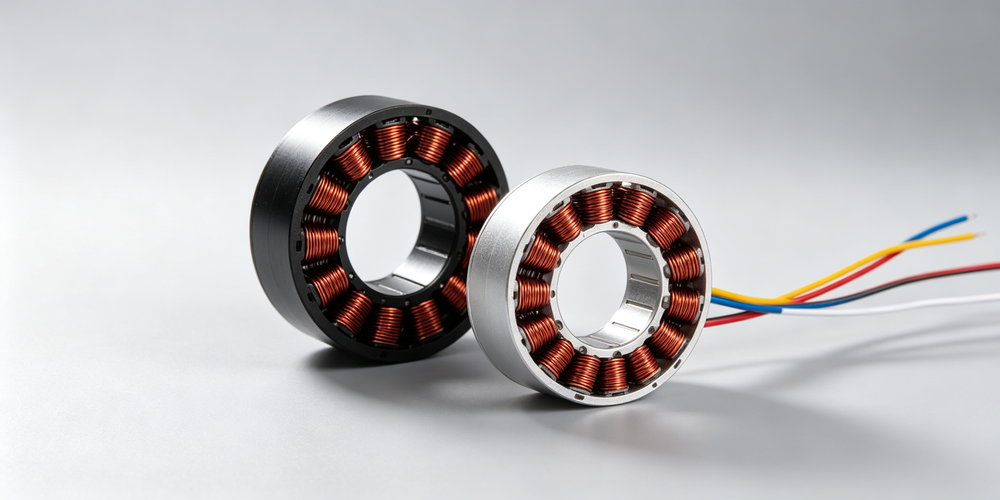
- Micro-diameter design (15/17/20mm) weighing as light as 25g, minimizing hand end-effector inertia.
- Near-zero cogging torque for extremely fluid and smooth finger articulation.
- Strict batch consistency ensuring precise multi-finger synchronous grasping.
2. Micro Precision Planetary Gearhead
- Micro planetary gearhead (30:1 / 30.25:1 ratio) delivering high torque density in a miniature envelope.
- Superior precision for fine fingertip positioning and delicate micro-force holding.
- Excellent mechanical efficiency minimizing localized thermal dissipation inside dexterous hands.
3. Ultra-Micro Absolute Encoder
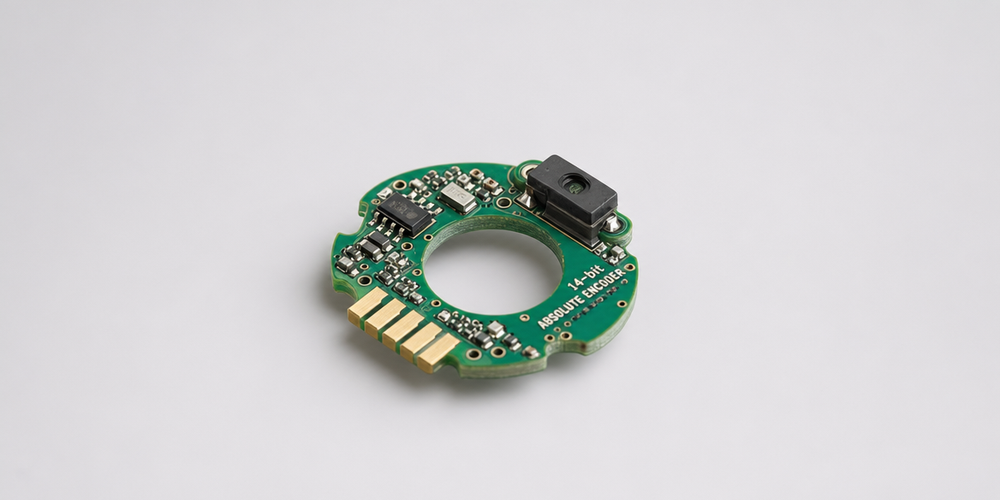
- Embedded 14-bit single-turn absolute encoder integrated into miniature space.
- Instant power-on angular recognition; eliminates homing routines for faster task initiation.
- Dust and oil-resistant magnetic sensing technology for reliable continuous operation.
4. Integrated FOC Driver
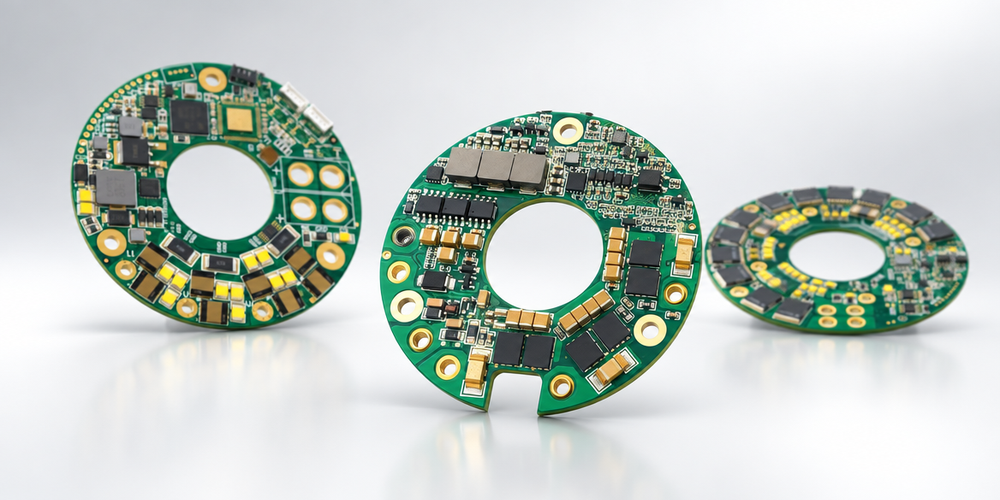
- Fully integrated micro-driver; eliminates external driver boards for standalone finger control.
- Dual Mode (Torque/Position): Allows delicate compliance control for fragile object handling.
- Low power consumption (<200mA operating current) prolonging battery run-times.
Key Features
| Extremely light | from 25 g per joint, cutting end-effector inertia for snappier finger starts and direction changes |
| Small size, real torque | high integration density gives useful output in a minimal envelope |
| Micro footprint | 15–20 mm outer diameter leaves room for structure and wiring |
| Drive built in | integrated electronics, ready to go |
| Single-turn absolute encoder | 14-bit, knows its position at power-on |
| Flexible communication | CAN with CIA 301/402 support, or RS485 with custom protocol support |
Applications — for joints where size, weight, and integration density set the limits
- Dexterous hands and grippers: per-finger actuation for humanoid hands and multi-finger grippers
- Fine end-effector tasks: grasping, pressing, and twisting that need coordinated multi-finger motion
- Medical and surgical instruments: small joints in surgical robot end-effectors and precision devices
- Electronics assembly and precision handling: connector insertion, precision gripping, lab automation, parcel sorting
- R&D and education: micro-robot and biomimetic hand platforms that use many small joints
Selection Notes
- Communication & supply: all three models share RS485 / CAN communication, 12 / 24 VDC supply, and no through-bore
- Pick by space: tightest space? go 15 series. Need more output? 20 series.
- Full specs: per-model details (phase current / peak torque) in the complete datasheet
Request a Quote
Need selection support or a custom solution? Contact RoBox Robotics for a quote.